Robotic Joint Actuators
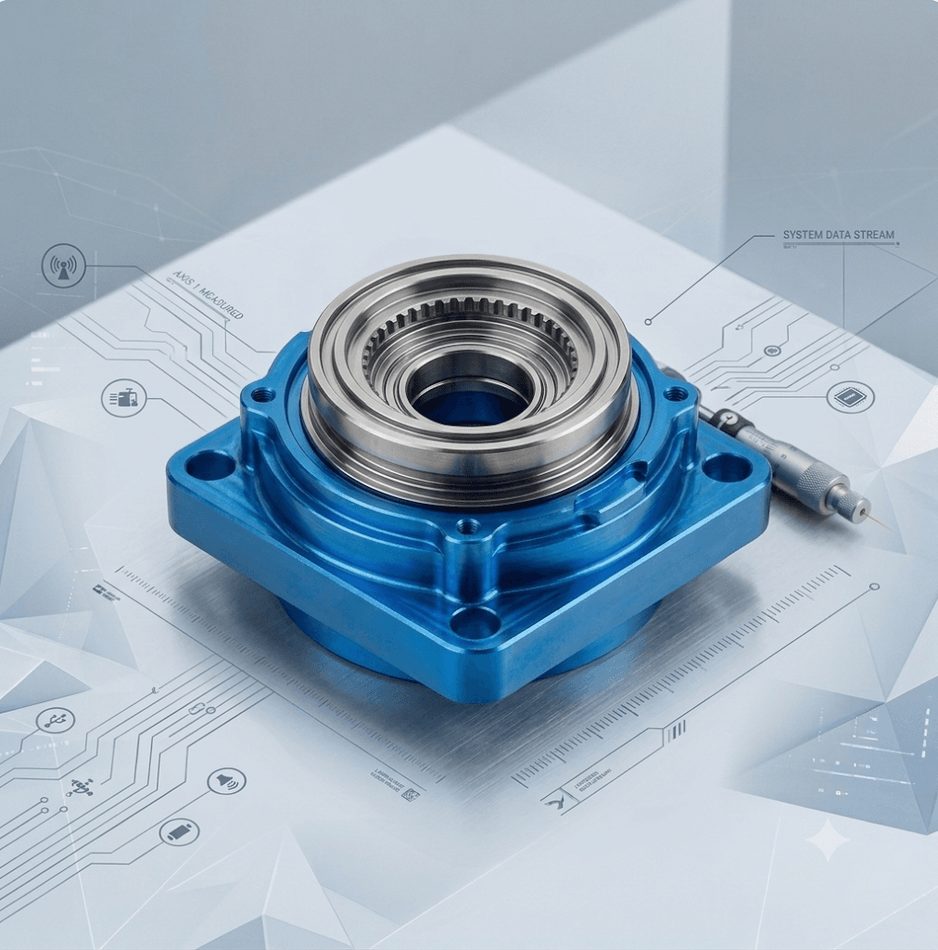
Sango All-in-One Robotic Joint Actuators integrate a zero-backlash strain wave reducer, frameless BLDC torque motor, dual 20-bit absolute encoders, power-off safety brake, and intelligent EtherCAT servo driver within an ultra-compact hollow-bore housing.
Sango Automation Limited is a leading innovator in smart modular robotic actuation in China. We supply integrated joint modules engineered to dramatically simplify collaborative robot (Cobot), exoskeleton, and humanoid robot design.
Features & Advantages
High power density, plug-and-play modular integration, and true dual-loop absolute position feedback.
All-in-One High-Density Modular Integration
Combines motor, zero-backlash reducer, dual encoders, driver, and holding brake into a single plug-and-play actuator, reducing robotic arm development time by 70%.
Dual 20-bit Absolute Encoders (Input & Output)
Output-side absolute encoder directly compensates for mechanical flexspline torsional windup, delivering absolute repeatability without homing cycles.
Large Central Hollow Shaft Bore
Generous central aperture allows power cables, sensor lines, Ethernet, and pneumatic tubing to pass directly through the joint center without external tangling.
Real-Time EtherCAT / CANopen Bus Control
Supports CiA 402 drive profile with CSP (Cyclic Synchronous Position), CSV, and CST torque control modes at 1 kHz synchronous cycle times.
Technical Specifications
Core performance data across compact, medium, and heavy-duty robotic joint module series.
| Model / Parameter | Compact Series (RJ-60/80) | Heavy-Duty Series (RJ-115/142) |
|---|---|---|
| Outer Diameter / Length | Ø 60–80 mm / 75–95 mm | Ø 115–142 mm / 110–140 mm |
| Rated / Peak Output Torque | 10–35 N·m / 30–100 N·m | 70–250 N·m / 200–650 N·m |
| Rated / Max Output Speed | 30 / 60 RPM | 20 / 45 RPM |
| Operating Voltage | 24V / 48V DC | 48V / 310V DC |
| Backlash / Lost Motion | ≤ 0.1 arcmin (Zero Backlash) | ≤ 0.08 arcmin (Zero Backlash) |
| Encoder Resolution | Dual 20-bit (1,048,576 CPR) | Dual 21-bit (2,097,152 CPR) |
| Communication Bus | EtherCAT / CANopen / RS485 | EtherCAT / CANopen (CiA 402) |
Integrated Actuator vs. Traditional Discrete Assembly
Why modern robotic designers choose integrated joint actuators over discrete motor-gearbox-drive assemblies.
| Design Aspect | Sango Integrated Actuator | Discrete Components Assembly |
|---|---|---|
| Assembly & Wiring Time | Plug-and-play; 5-minute single cable connection | Requires custom mounting plates, couplers, complex wiring |
| Volume & Weight | 50% smaller envelope, 40% lighter weight | Bulky footprint with multiple couplers and brackets |
| Positional Accuracy | Dual closed-loop encoders eliminate gear flexure | Single motor encoder suffers from gearbox lost motion |
| Cabling Management | Clean through-hole hollow bore routing | External wire loops subject to fatigue and snagging |
| Reliability & Sealing | Factory sealed IP65/IP67 enclosure | Multiple joints prone to dust/oil ingress |
Application Scenarios
Essential for 6-axis cobots, humanoid humanoid bipedal legs and arms, medical rehabilitation exoskeletons, mobile manipulator rovers, and optical camera pan-tilts.